
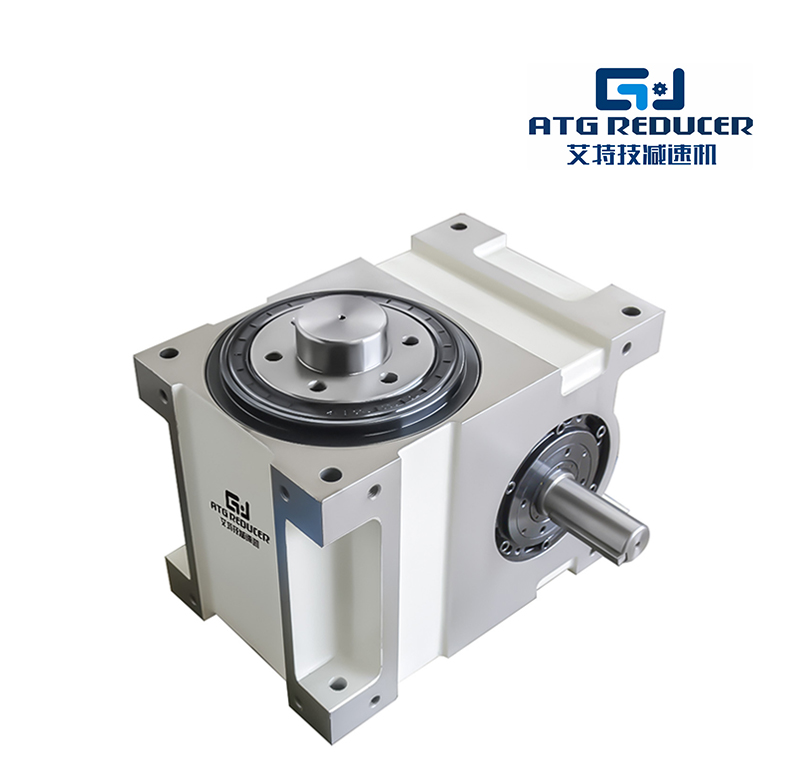
Gear reducer and rotary platform solutions for robotics are essential motion control components used to improve torque, position accuracy, repeatability, and load-handling performance in automated systems. As robotics adoption continues to expand across manufacturing, logistics, inspection, assembly, medical automation, and smart warehouses, the demand for reliable robotic gear reducers and rotary platform solutions has increased significantly. These components help robots move with precision, handle heavier payloads, maintain stable motion, and achieve consistent output in demanding industrial environments.
In modern robot design, motion accuracy is not achieved by motors alone. A motor provides speed and power, but a gear reducer converts that high-speed input into usable torque while reducing output speed and improving control. A rotary platform provides stable rotational motion, positioning, indexing, or continuous turning for automation tasks. Together, these technologies support compact, efficient, and highly accurate robotic motion systems.
This page provides a comprehensive, SEO-friendly overview of gear reducer and rotary platform solutions for robotics, including definitions, types, benefits, common specifications, selection factors, application areas, and performance considerations. The information below is industry-general and suitable for blogs, category pages, landing pages, and technical directory content.
Gear reducer and rotary platform solutions for robotics refer to mechanical motion transmission and positioning systems designed to support robot joints, axes, rotary tables, indexing devices, and precision automation equipment. These solutions are widely used in industrial robots, collaborative robots, CNC automation, pick-and-place systems, inspection stations, assembly cells, and material handling equipment.
A gear reducer is a mechanical device that reduces rotational speed while increasing output torque. In robotics, it allows a servo motor or other drive source to deliver stronger and more controlled output motion. A rotary platform is a rotating positioning device that supports controlled rotation of a workpiece, fixture, tool, or robotic axis. It is often used where repeatable angular positioning, smooth rotation, and compact motion control are required.
These two solutions are often paired because robotics systems need both torque multiplication and precise rotational positioning. By combining a suitable reducer with a stable rotary platform, engineers can create motion systems that are compact, accurate, durable, and energy-efficient.
Robotic applications place demanding requirements on motion control. Robots often need high torque at low speed, low backlash, compact installation, long service life, and smooth response under repeated cycles. A robotics gear reducer addresses these requirements by adapting motor output to the needs of the application.
Without a reducer, motors would need to be oversized to generate sufficient torque, which increases cost, weight, and power consumption. With the right gear reducer, a robot can operate more efficiently while maintaining accurate motion and stable performance. This is especially important in articulated robots, SCARA systems, rotary axes, and automated turntables.
In many cases, the reducer is one of the most important elements affecting robot precision. Parameters such as backlash, torsional rigidity, efficiency, and repeatability directly influence how a robotic system performs.
Rotary platform solutions for robotics provide controlled rotational movement for a wide range of automation tasks. These platforms can function as positioning tables, indexing stations, rotary fixtures, dual-axis supports, or integrated motion modules. In robotics manufacturing, rotary platforms improve workflow efficiency by enabling robots to access parts from multiple angles, complete operations in fewer steps, and maintain precise alignment.
A rotary platform may be used for inspection, welding, dispensing, assembly, testing, labeling, or loading/unloading. In collaborative and industrial robotic systems, rotary platforms often help reduce cycle time and improve process consistency. When combined with gear reducers, they create a stable and repeatable motion structure that is suitable for demanding industrial environments.
| Advantage | Description | Robotics Benefit |
|---|---|---|
| High Torque Output | Reduces motor speed while multiplying torque | Supports heavier loads and stronger robotic motion |
| Improved Positioning Accuracy | Reduces unwanted motion error and enhances control | Enables precise robotic movement and repeatability |
| Compact Design | Delivers high performance in a small package | Helps save space inside robot joints and automation cells |
| Low Backlash Options | Minimizes play between input and output shafts | Improves accuracy in sensitive robotic applications |
| High Load Capacity | Supports radial, axial, and moment loads depending on design | Improves stability under continuous industrial use |
| Energy Efficiency | Allows smaller motors to achieve required output torque | Reduces operating power and system cost |
| Better Motion Stability | Supports smooth rotation and reduced vibration | Enhances process quality and robotic consistency |
| Long Service Life | Designed for repeated cycles and heavy-duty use | Improves uptime in industrial robotics systems |
There are several types of robotic gear reducers, and each has distinct advantages depending on the application, precision needs, torque load, and installation space. Understanding these types helps engineers choose the most suitable solution for robot joints and rotary motion systems.
Planetary reducers are widely used in robotics because they offer compact size, high torque density, and good efficiency. Their design includes a sun gear, planet gears, and an outer ring gear. This configuration distributes load across multiple gears, improving durability and performance.
Common robotics uses: servo-driven robots, indexing systems, rotary axes, automated machinery, and compact motion modules.
Harmonic reducers are known for very low backlash and high precision. They are often used in robot joints that require accurate angular positioning and smooth motion. Their flexible spline design supports excellent reduction ratios in a compact form factor.
Common robotics uses: articulated robot arms, collaborative robots, precision assembly, camera positioning, and inspection equipment.
Cycloidal reducers provide strong shock resistance, high stiffness, and excellent load capacity. They are suitable for applications requiring durability under repetitive and heavy-duty conditions. Many industrial robots use cycloidal mechanisms in joint systems due to their stability and long life.
Common robotics uses: industrial robot axes, welding robots, heavy-load automation, and high-cycle systems.
Worm reducers offer high reduction ratios and compact structure. They may also provide self-locking characteristics in some configurations. While not always the first choice for ultra-precision robotic joints, they are useful in moderate-speed rotary platforms and positioning systems.
Common robotics uses: rotary tables, basic automation platforms, conveyors, and light-duty positioning equipment.
Bevel reducers change the direction of motion between intersecting shafts. They are helpful where space constraints or system geometry require angular transmission. In robotics, bevel reducers are often incorporated into compact motion assemblies and rotary access systems.
Common robotics uses: custom axes, transfer systems, and compact robotic fixtures.
Rotary platform solutions for robotics can vary from simple turntables to advanced precision positioning stages. The correct platform type depends on payload, rotation angle, speed, repeatability, and integration requirements.
| Rotary Platform Type | Main Function | Typical Robotics Use |
|---|---|---|
| Indexing Rotary Table | Moves between fixed positions | Assembly, inspection, loading stations |
| Continuous Rotary Table | Provides uninterrupted rotational motion | Conveying, labeling, process transfer |
| Precision Rotary Stage | Delivers very accurate angular positioning | Vision systems, calibration, metrology |
| Heavy-Duty Turntable | Supports large payloads and stable rotation | Welding, material handling, large parts |
| Dual-Axis Rotary Platform | Enables rotation with tilt or multi-axis motion | Inspection, robotic camera movement, advanced automation |
| Servo-Driven Rotary Platform | Offers precise speed and position control | High-accuracy robotic workcells |
When evaluating gear reducer and rotary platform solutions for robotics, engineers should pay close attention to performance features that affect motion quality, reliability, and integration ease.
The table below provides a general reference for the most common specifications used when selecting a robotics gear reducer. Actual values vary by design, size, and application needs.
| Specification | Typical Meaning | Why It Matters |
|---|---|---|
| Reduction Ratio | Commonly ranges from low to very high depending on reducer type | Determines speed reduction and torque multiplication |
| Rated Torque | Continuous output torque under normal operating conditions | Helps determine load-handling capability |
| Peak Torque | Short-duration maximum torque | Supports acceleration and shock loads |
| Backlash | Measured in arcminutes or angular units | Directly affects positional accuracy |
| Efficiency | Percentage of input power converted to output power | Impacts heat, energy use, and system performance |
| Input Speed | Maximum supported rotational speed | Must match motor and application requirements |
| Output Speed | Reduced rotational speed after transmission | Defines motion behavior at the robotic joint or axis |
| Torsional Stiffness | Resistance to angular deflection | Improves control precision and repeatability |
| Service Life | Expected working duration under specified load conditions | Supports planning for maintenance and uptime |
| Mounting Type | Flange, shaft, hollow shaft, or custom mount | Ensures compatibility with robotic architecture |
Rotary platform solutions for robotics also require a clear understanding of key specifications. These parameters help determine whether the platform is appropriate for precision positioning, heavy loads, or high-cycle operation.
| Specification | Typical Meaning | Why It Matters |
|---|---|---|
| Table Diameter | Size of the rotating surface | Determines workpiece fit and stability |
| Payload Capacity | Maximum supported load | Critical for safety and performance |
| Rotation Range | Full rotation or indexed angle range | Defines system flexibility |
| Positioning Accuracy | How precisely the platform reaches target angles | Important for robotics and inspection tasks |
| Repeatability | Ability to return to the same position consistently | Essential for automation consistency |
| Drive Type | Servo, stepper, direct drive, or geared drive | Affects control and performance characteristics |
| Speed | Maximum rotational speed | Impacts cycle time and productivity |
| Moment Load Capacity | Resistance to off-center load forces | Important for uneven or extended workpieces |
| Motor Compatibility | Mounting and drive interface support | Ensures smooth system integration |
| Control Interface | PLC, servo controller, CNC, or robot controller | Supports automation communication and operation |
Selecting the right gear reducer for robotics requires balancing precision, load, speed, size, and cost. A reducer that works well for one robot joint may not be suitable for another. The best choice depends on the application’s motion profile and performance targets.
Important selection criteria include:
The right rotary platform solution for robotics depends on whether the system needs indexed motion, continuous rotation, high accuracy, or heavy load support. The platform should also match the robot’s workflow and production requirements.
Key selection factors include:
Gear reducer and rotary platform solutions for robotics are used in a wide variety of automated processes. Their flexibility makes them valuable across many industries and robot architectures.
| Application | Role of Gear Reducer | Role of Rotary Platform |
|---|---|---|
| Robot Arms | Increases torque and precision at the joints | Supports part rotation or tool alignment |
| Welding Automation | Handles strong joint motion and load stability | Rotates parts for multi-angle welding |
| Pick-and-Place Systems | Improves speed control and repeatability | Positions parts for transfer and orientation |
| Assembly Lines | Supports accurate positioning | Indexes parts between workstations |
| Inspection and Vision | Enables fine movement adjustments | Rotates objects for multi-angle inspection |
| Packaging Automation | Supports smooth motion and consistent speed | Turns packages or product carriers |
| Medical Robotics | Allows precise, controlled movement | Supports sample or tool positioning |
| Material Handling | Provides torque for repeated movement | Rotates pallets, trays, or fixtures |
Industries choose gear reducer and rotary platform solutions for robotics because they improve both machine capability and production performance. These solutions support smarter automation by improving motion consistency and reducing mechanical stress.
The robotics industry continues to drive innovation in motion systems. As robot cells become more compact and more intelligent, gear reducer and rotary platform solutions are evolving to meet stricter requirements for precision, speed, efficiency, and integration.
Current trends include:
| Aspect | Gear Reducer | Rotary Platform |
|---|---|---|
| Main Purpose | Reduce speed and increase torque | Provide controlled rotation and positioning |
| Primary Benefit | Motion power conversion | Rotational workpiece or axis control |
| Typical Location | Robot joint, actuator, drive train | Workstation, table, axis module |
| Key Performance Factor | Backlash, torque, efficiency | Accuracy, payload, rotation stability |
| Common Use | Servo motion transmission | Part positioning and rotation |
| Integration Goal | Make motion stronger and more precise | Make rotation stable and repeatable |
When researching gear reducer and rotary platform solutions for robotics, the following technical terms are commonly encountered:
Gear reducer and rotary platform solutions for robotics are foundational technologies in industrial automation and precision motion control. Gear reducers provide torque multiplication, speed reduction, and improved positioning accuracy, while rotary platforms support stable and repeatable rotational motion in a wide range of robotic applications. Together, these solutions help robots operate with higher productivity, improved reliability, and better motion quality.
For companies, engineers, and automation planners seeking industry information on robotics gear reducers and rotary platform solutions, the most important factors to evaluate include torque capacity, backlash, repeatability, mounting compatibility, efficiency, payload handling, and service life. By selecting the right motion components, it is possible to build compact, durable, and high-performance robotic systems that meet modern production demands.
As robotics continues to advance, demand for high-precision gear reducers and robust rotary platform solutions will remain strong across manufacturing, logistics, inspection, assembly, and custom automation. These technologies will continue to play a central role in enabling reliable, scalable, and intelligent robotic motion.
gear reducer and rotary platform solutions for robotics, robotics gear reducer, rotary platform solutions, robotic motion control, precision gear reducer, industrial rotary platform, low backlash reducer, high torque gear reducer, robotic rotary table, automation motion system, robotic positioning solution, rotary axis for robotics, industrial automation components, robot joint reducer, precision rotary stage
Trang web này sử dụng cookie để đảm bảo bạn có được trải nghiệm tốt nhất trên trang web của chúng tôi.

 Chinese
 EN
 Español
 Pусский
 Deutsch


 Điện thoại
Bình luận
(0)